Inside Out Library · Explore
A Distributed Model for Mobile Robot Environment-Learning and Navigation
Defense Technical Information Center · 1990 · 28 pictures
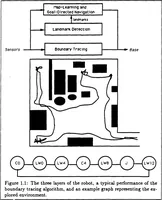
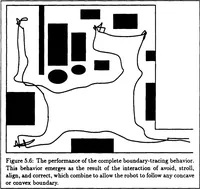
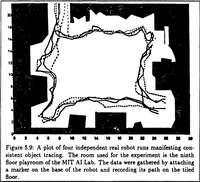
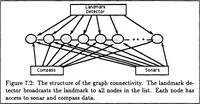
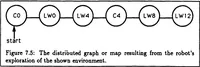
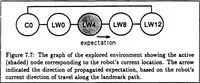
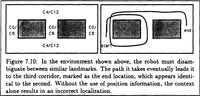
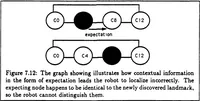
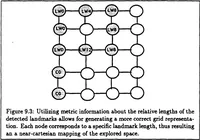
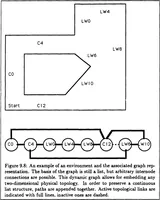
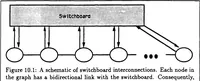
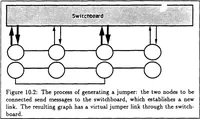
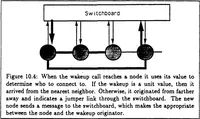
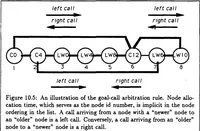
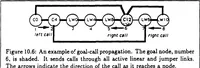
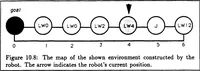
A 1990 technical report by Maja Mataric of the MIT Artificial Intelligence Lab, distributed through the Defense Technical Information Center, modelling how a mobile robot learns and navigates its environment. The pictures are plain line diagrams: landmark maps with labelled nodes, linked graph chains, and shaded node sequences showing call propagation and expectation. A designer could take their clean node-and-link diagram vocabulary as a schematic style for network or route graphics.
Mataric, Maja J · Massachusetts inst of tech cambridge artificial intelligence lab · Omnidirectional · Autonomous navigation · Robots · Detectors · Models · Real time · Distribution · Dynamics · Layers · Physical properties · Graphs · Paths · Theses · Reactivities · Nodes · Ultrasonics · Planning · Mobile · Barriers · Low level · Language · Maps · Power · Behavior · Architecture · Learning · Navigation reference · Detection · Environments · Methodology · Experimental data
Internet Archive · Defense Technical Information Center · Public domain (US government work) · More from this library